Meet Our Robot, Orion
2026–2027 SEASON
Built by us. Still a work in progress.
Meet our robot! What started as a chassis and a bunch of ideas is slowly turning into something we can actually compete with.
We've spent hours designing, building, programming, and figuring out why things aren't working the way we expected. It's been a lot of trial and error, but that's also where we've learned the most.
Here's a look at how our robot has changed throughout the season.

Under our Robot's Hood
Drivetrain
-
Four-Wheel Mecanum Drive – Allows movement in all directions, including sideways and rotation.
-
goBILDA Motors – Power our drivetrain for responsive and controlled movement.
-
Omnidirectional Movement – Enables quick maneuvering without needing to turn the robot first.
-
Precise Positioning – Helps us align quickly and accurately for scoring.
Mechanisms
-
Intake System – Collects game pieces efficiently.
-
Transfer System – Moves game pieces from the intake to the scoring mechanism.
-
Rotating Turret – Allows independent aiming without repositioning the entire robot.
-
Scoring Efficiency – Designed for fast, consistent, and reliable scoring throughout a match.
AUTONOMOUS
-
Autonomous Navigation – Designed to navigate the field with minimal driver input.
-
Target Detection – Developing vision-based detection to identify scoring targets.
-
AprilTag Detection – Working to improve robot positioning and localization.
-
Vision-Assisted Aiming – Aims to improve targeting accuracy and scoring consistency.
2026–2027 Build Progress
August 2026 — Where It All Started
We started with our drivetrain and a lot of ideas.
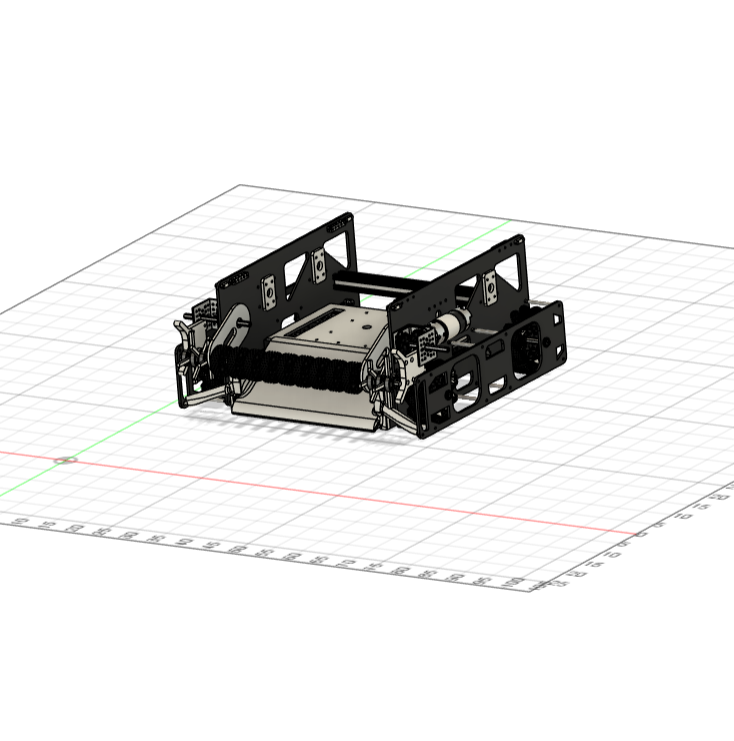
What we worked on: Drivetrain, game strategy, initial designs, and mechanism prototypes.
What we learned: Having an idea is easy. Making it work is the challenge.
September 2026 — Getting Into the Game
We learned the game and spent a lot of time figuring out how we wanted our robot to work.

What we worked on: Understanding the game rules, developing our match strategy, exploring robot designs, and deciding which mechanisms would work best.
What we learned: A good robot starts with a solid strategy. We learned how important it is to understand the game before deciding what to build.
October 2026 — Getting Things Moving
Our robot is finally starting to take shape!
What We're Working On: We continue to work on our intake, internal mechanisms, fixed turret, and programming as we prepared for our first scrimmage and league meet.
What we Learned:
-
Turret System: Don't overtighten the REV gearbox! It can cause the gears to bind and put extra strain on the motors.
-
Intake System: More wheels don't always mean better performance. We learned that a two-layer intake design works better when we eliminate dead zones where balls can get stuck.
-
Transfer System: Our transfer system needs to be reliable and consistently push the ball all the way into the turret.
-
Build Process: We learned that a waterfall approach (finishing one stage before moving to the next) wasn't working well for us. An agile approach with constant testing, feedback, and improvements is much more effective.
